Team Members

Faculty, researchers, and students working on embodied intelligence: embodied foundation models, world models, and robot learning.

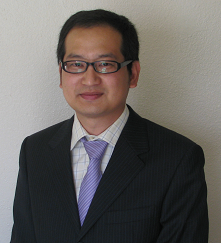
Portrait of Dr. Yunbo Will Zhang

Yunbo "Will" Zhang

Professor · Doctoral Supervisor
Centre for Fundamental and Frontier Sciences, Hong Kong Institute of Science & Innovation, Chinese Academy of Sciences (HKISI-CAS)
5,712Citations 22h-index 30i10-index Google Scholar >

Prof. Yunbo "Will" Zhang is a Professor (Research Fellow) at the Hong Kong Institute of Science & Innovation, Chinese Academy of Sciences, and a Professor and doctoral supervisor at the University of Chinese Academy of Sciences. He was recruited to HKISI-CAS through the CAS high-level talent program.

He received his B.S. from Shandong University, his M.S. from Huazhong University of Science and Technology, and his Ph.D. in Mechanical and Automation Engineering from The Chinese University of Hong Kong in 2012. He then spent twelve years in research and teaching in the United States, as a postdoctoral researcher at Purdue University (2014–2017), Assistant Professor at Tennessee Technological University, and tenured Associate Professor at Rochester Institute of Technology.

His current research focuses on embodied intelligence, including embodied foundation models, world models and robot learning; his earlier work spans human-robot collaboration, AI for smart manufacturing and AR/VR interaction. His work has received the 2024 ASME CIE Technical Committee Leadership Award and the Silver Medal at the 2019 Geneva International Exhibition of Inventions.

He serves as an Associate Editor for international journals including Frontiers in Robotics and AI and Journal of Intelligent Manufacturing.

Research Staff

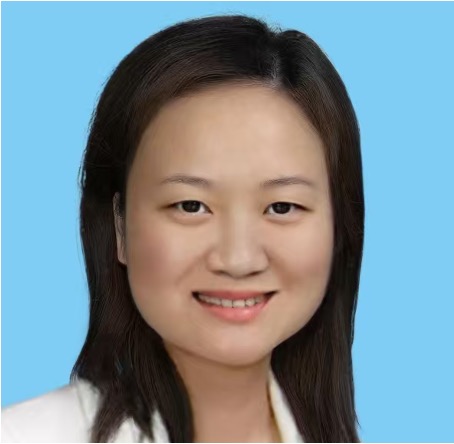
Portrait of Dr. Qinqin Xiao
Ph.D. in AR/VR & AI

Qinqin Xiao

University of Rochester

Dr. Qinqin Xiao holds a Ph.D. in AR/VR and a Master's degree in Big Data & AI from the University of Rochester, advised by IEEE/ACM Fellow Prof. Jiebo Luo. She has long worked on XR/AI applications, digital twins, and immersive systems across educational and industrial domains.

She also brings rich management and industrial execution experience in cross-functional team coordination, supply chain alignment, and technology translation, playing an essential role in strategy, operational management, and industry partnerships within the team.
Ph.D. Students

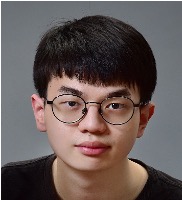
Portrait of Xiwen DengXiong
Ph.D. Student

Xiwen DengXiong

Rochester Institute of Technology (RIT)

Research focus: Human-robot collaboration, open-set recognition, robot learning, AR teleoperation, and multi-modal tactile perception for intelligent robotics.

Industry experience: Worked on robotics and XR interaction at TikTok Pico AR and contributed to the XRobotToolkit framework and tactile-vision robot learning systems.

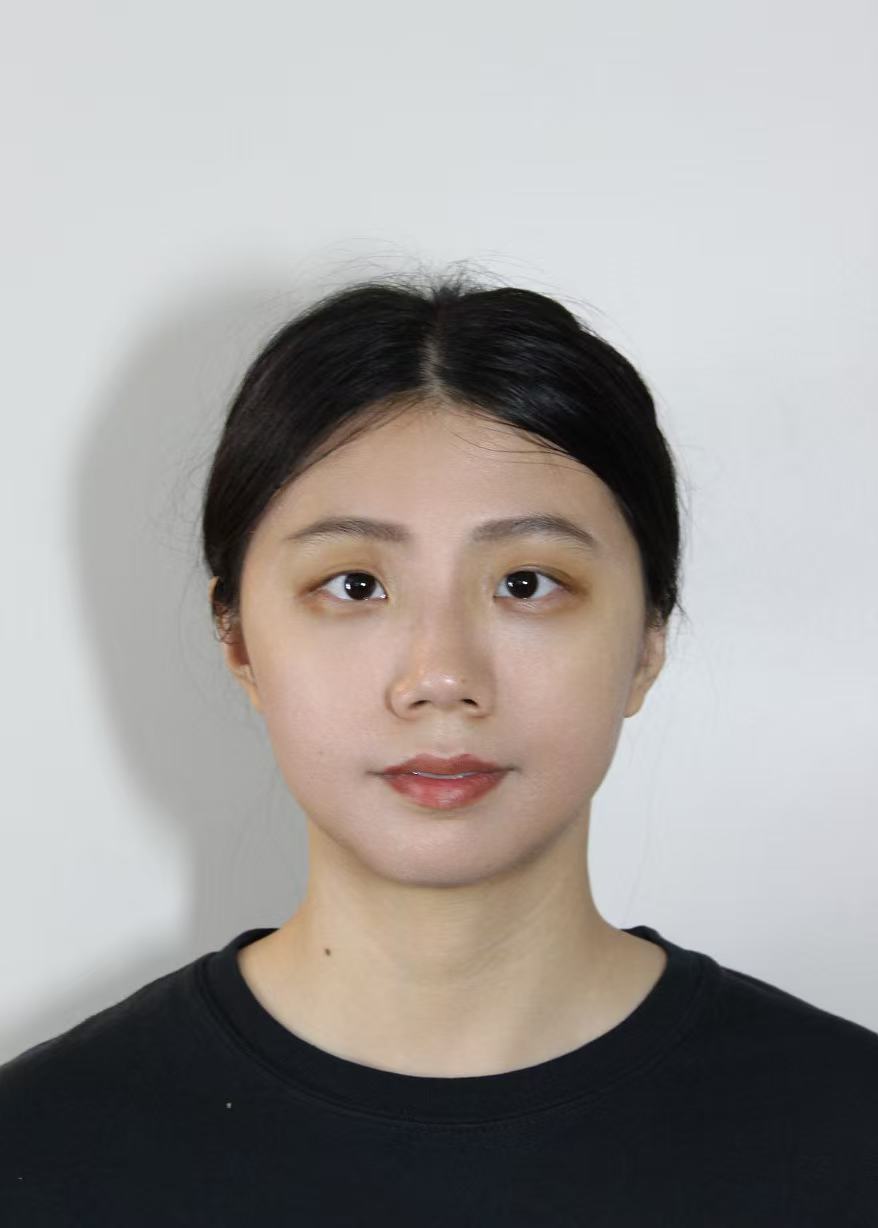
Portrait of Xueting Wang
Ph.D. Student

Xueting Wang

Rochester Institute of Technology (RIT)

Research focus: Human-robot collaboration, open-set perception, robot learning, AR teleoperation interfaces, and tactile sensing integration.

Project experience: Designed the VLAbot human-vision-language-action interaction framework for manufacturing assembly and developed the HALO hierarchical long-horizon manipulation system.

Portrait of Zhenshan Liang
Ph.D. Student

Zhenshan Liang

Concordia University

Research focus: 3D scene reconstruction, image processing, machine learning, world models, and robot vision.

Project experience: Proposed a geometry-processing indoor depth completion framework; established automated workflows for sensor manufacturing; researched deep-learning-based aircraft detection.

Portrait of Yuhui Wang
Ph.D. Student

Yuhui Wang

Dept. of Mechanical and Automation Engineering, CUHK · M.S. & B.S. Tianjin University

Research focus: world models, VLA models, 3D scene understanding, and closed-loop robot control.

Industry experience: World model engineer at Miaodong Technology; autonomous driving algorithm engineer at Li Auto, contributing to three generations of driving systems (map-free NOA, end-to-end, and VLA) through mass production; perception work at DiDi on self-supervised video pre-training and road object detection.

Portrait of Zhen Fan
Ph.D. Student

Zhen Fan

Dept. of Mechanical and Automation Engineering, CUHK · M.S. NUS · B.S. BJTU

Research focus: High-fidelity digital twins, synthetic data generation, multi-modal cognitive agents, embodied intelligence, sim-to-real transfer, and human-robot collaboration.

Project experience: Developed NVIDIA Omniverse synthetic data pipelines, constructed knowledge-augmented human-centric manufacturing systems with LLMs and RAG, with deep embedded and robotic hardware control experience.

Master Students

Portrait of Chenrui Chen
Master Student

Chenrui Chen

Hong Kong University of Science and Technology (Guangzhou)

Research focus: VLA models and end-to-end robot control, mapping vision, language and robot state directly to actions for closed-loop manipulation, with attention to robot data collection, model training and real-robot deployment.

Research & practice: First author of CopilotTele, a Best Student Paper Award Finalist at IEEE CASE 2026; full-stack robot hardware and software experience, including leading robotics projects at a major tech company and presenting at leading developer conferences.

Interested in Joining FIR Lab?

We are looking for postdocs, Ph.D. students, engineers, research assistants and visiting interns in embodied intelligence to join us at HKISI-CAS in Hong Kong.

View Open Positions