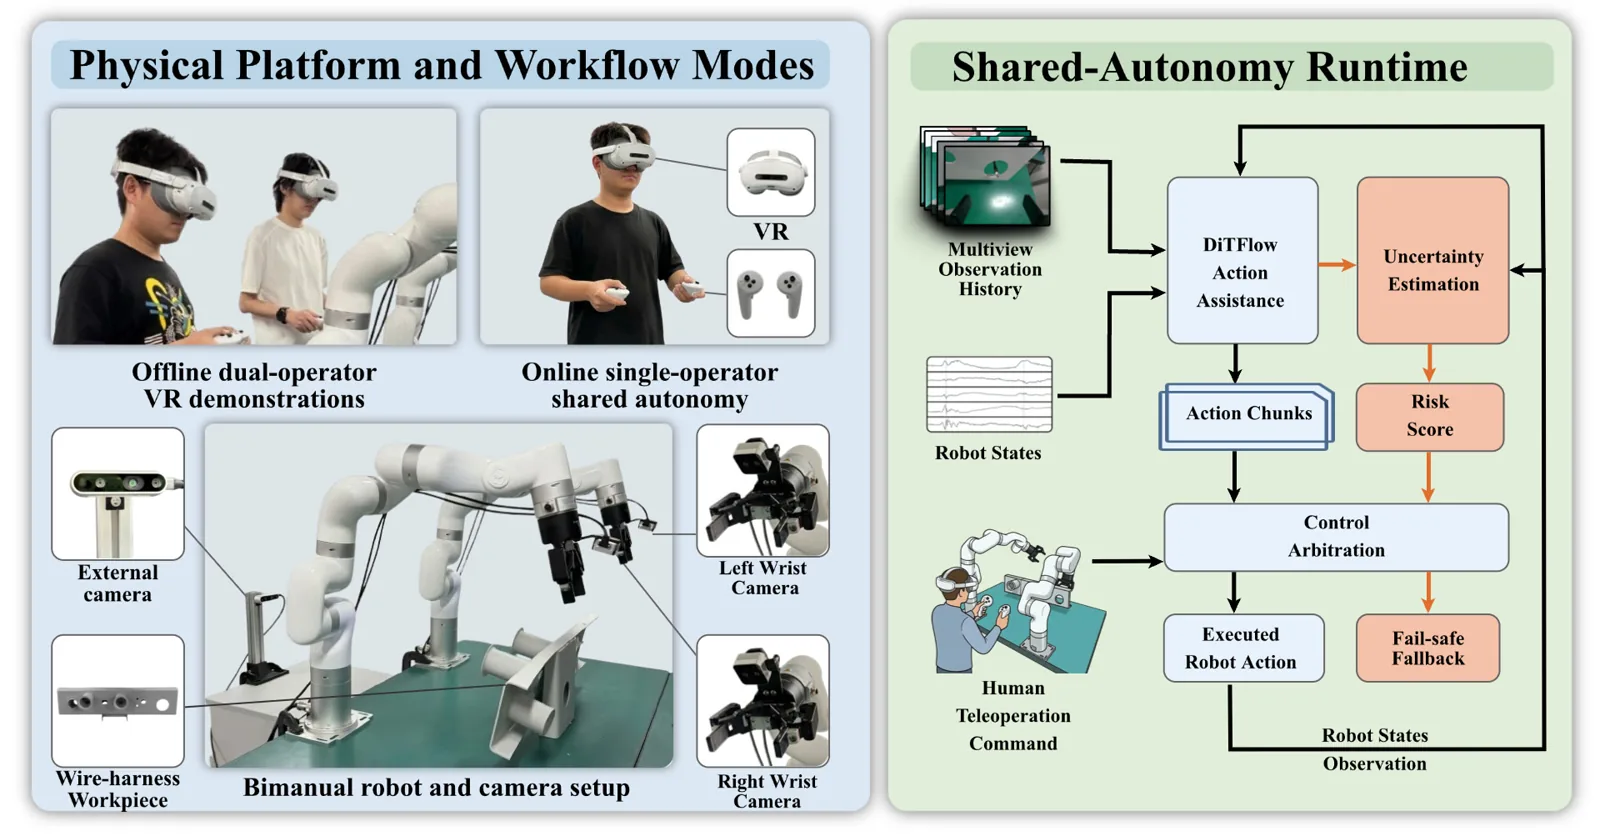
CopilotTele: A Shared-Autonomy Teleoperation System for Bimanual Manufacturing Assembly with Risk-Guided Arbitration
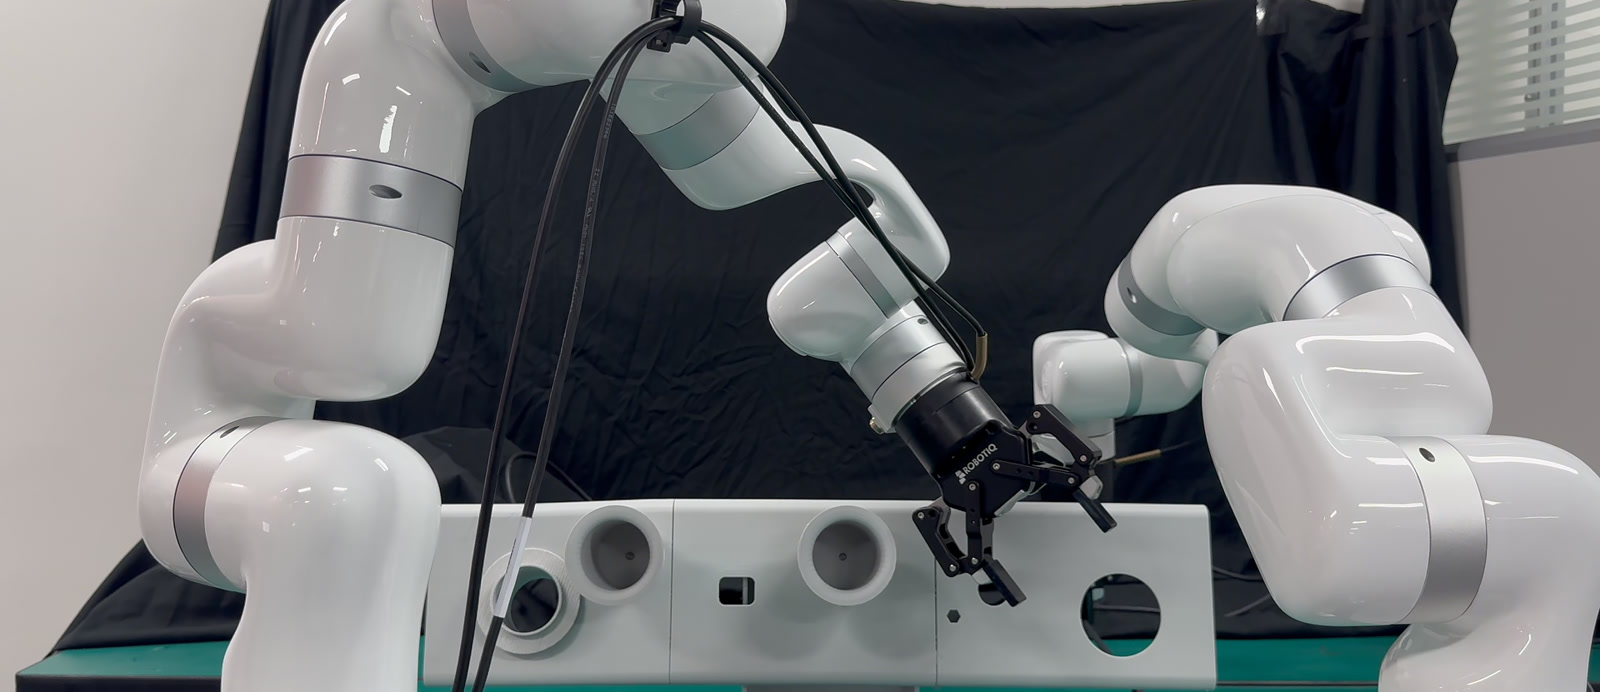
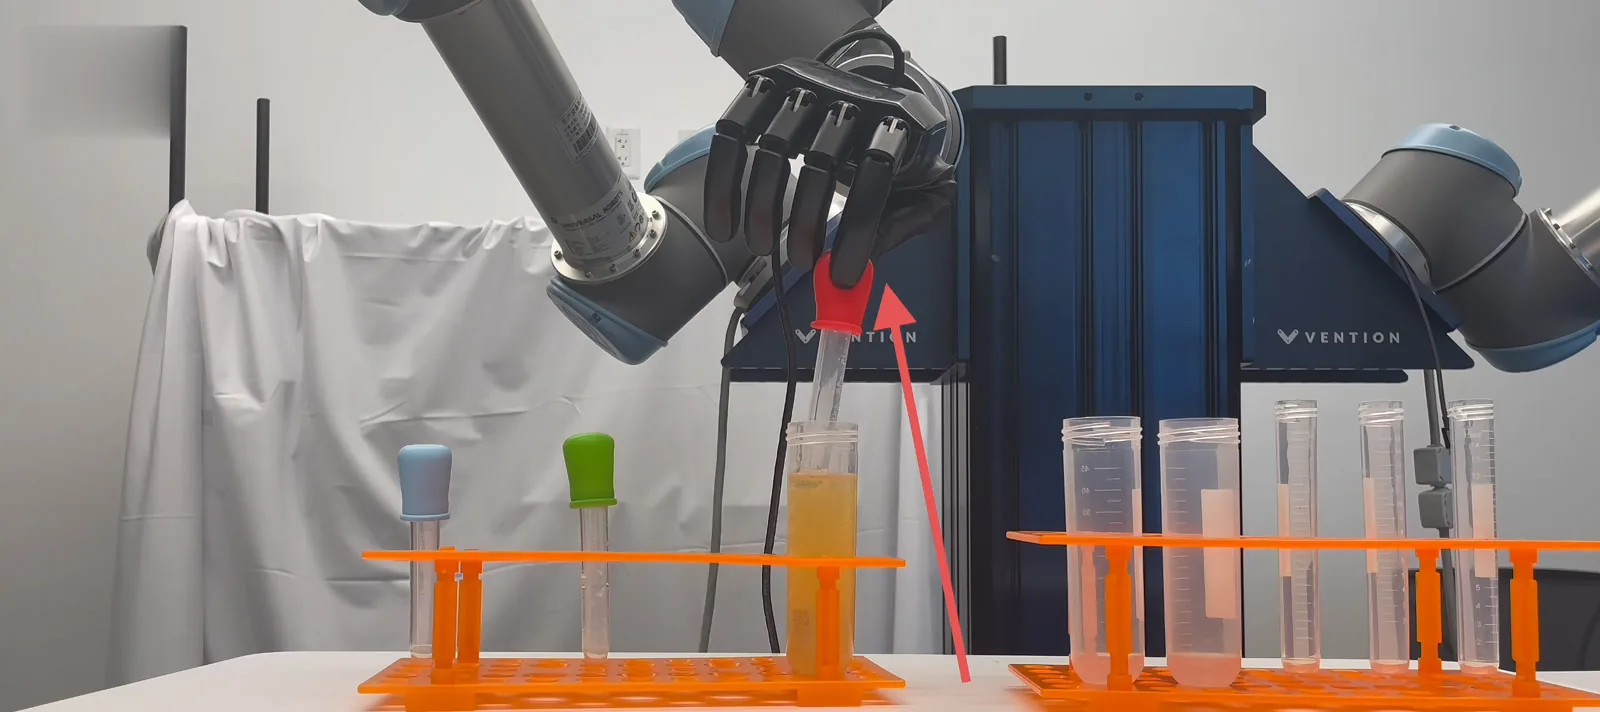
Risk-guided shared autonomy for bimanual wire-harness assembly, combining DiTFlow action assistance with on-demand human takeover.

Embodied AI · Foundation Models · Robot Learning
We work on embodied intelligence: building embodied foundation models such as VLA and WAM that let robots understand tasks and the physical world, and act reliably in real environments.
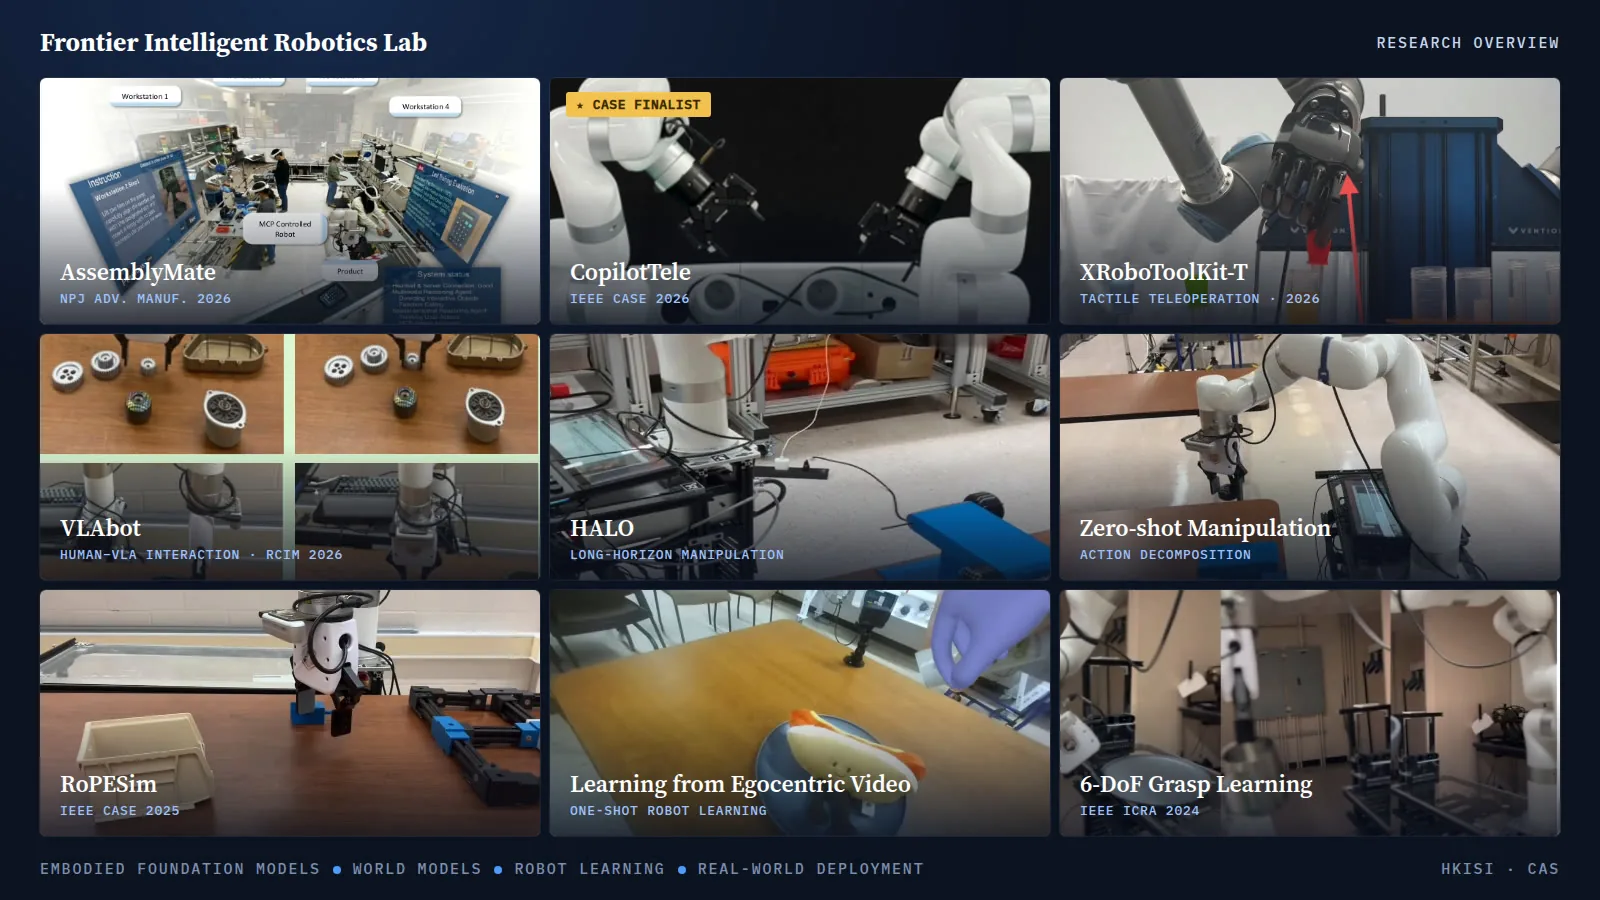
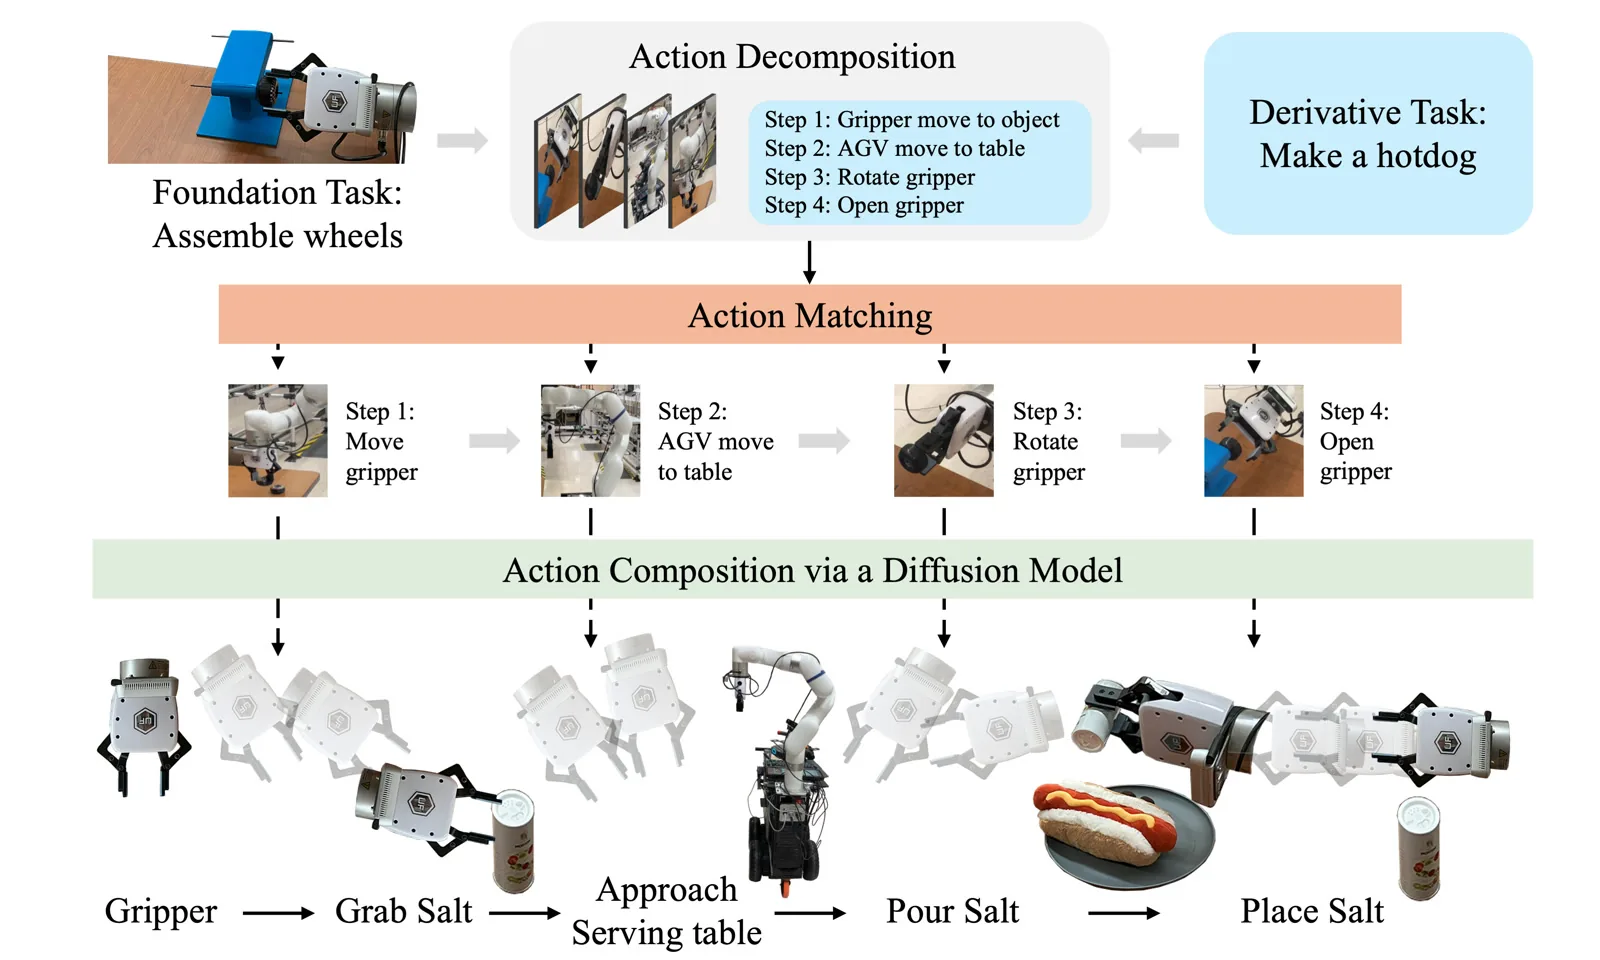
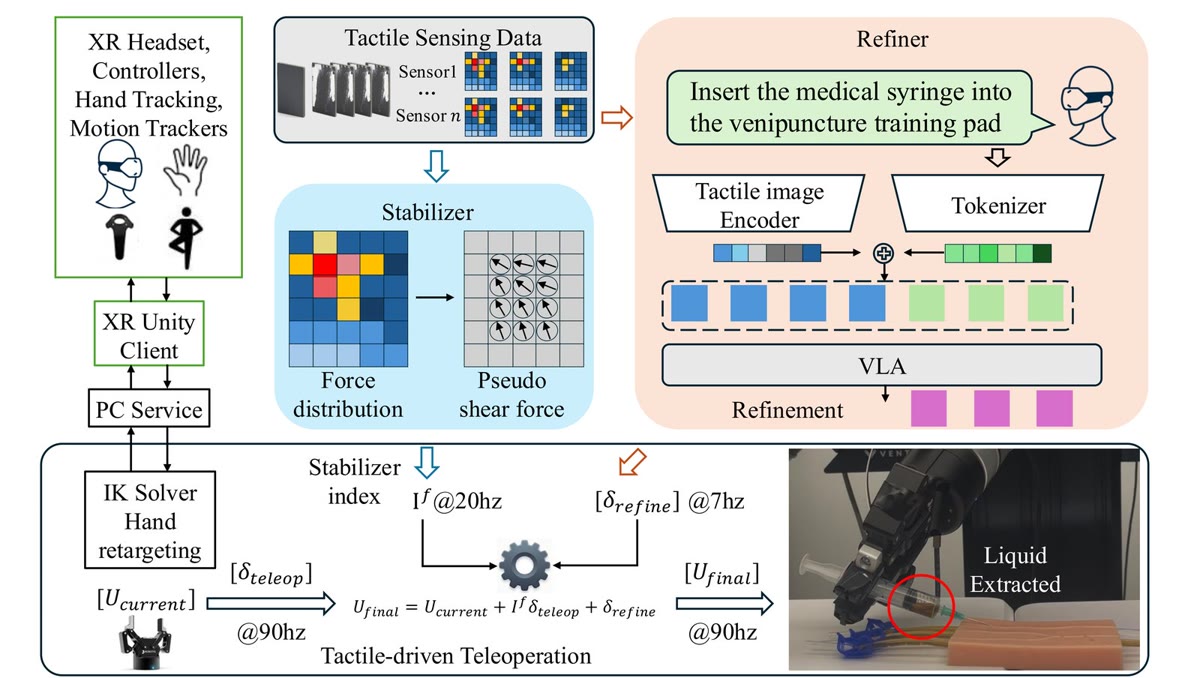
How can robots understand the physical world and turn that understanding into reliable, generalizable manipulation skills?
Risk-guided shared autonomy for bimanual wire-harness assembly, combining DiTFlow action assistance with on-demand human takeover.
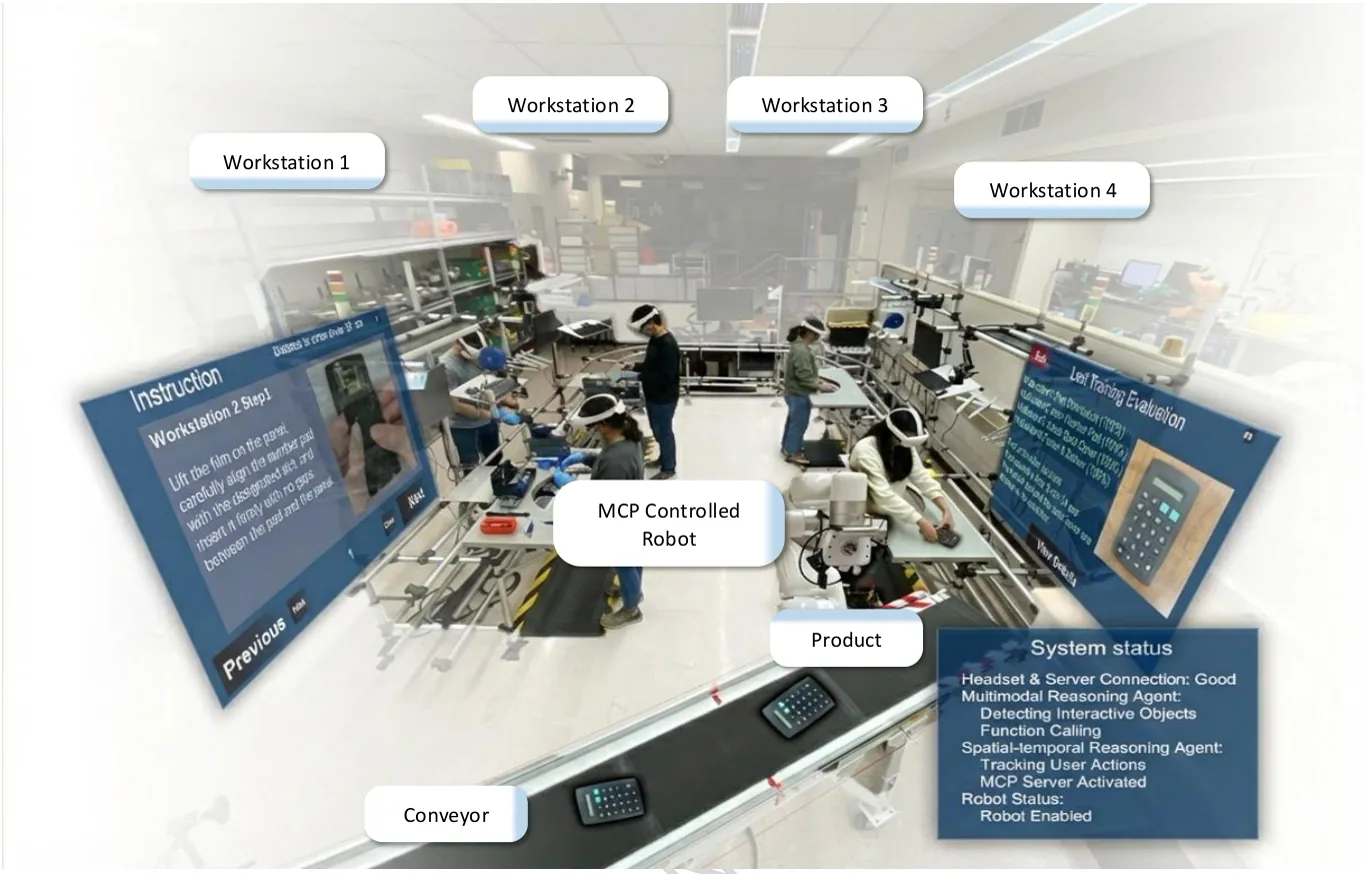
An AI-XR co-worker that combines multimodal and spatial-temporal reasoning agents to guide operators, evaluate assembly actions and coordinate a collaborative robot.
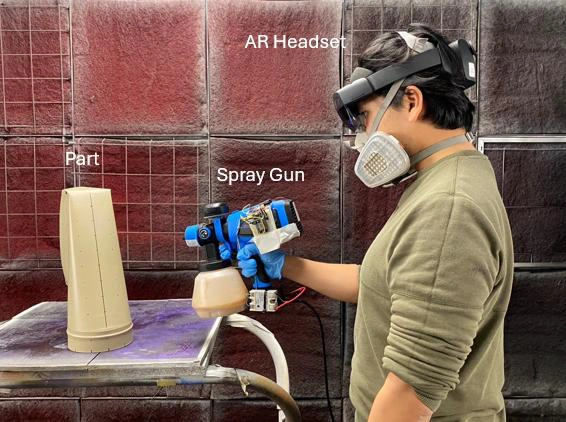
AR feedback for manual spray painting: a sensorized spray gun, coating-deposition simulation and an AR headset show coverage on complex surfaces in real time.
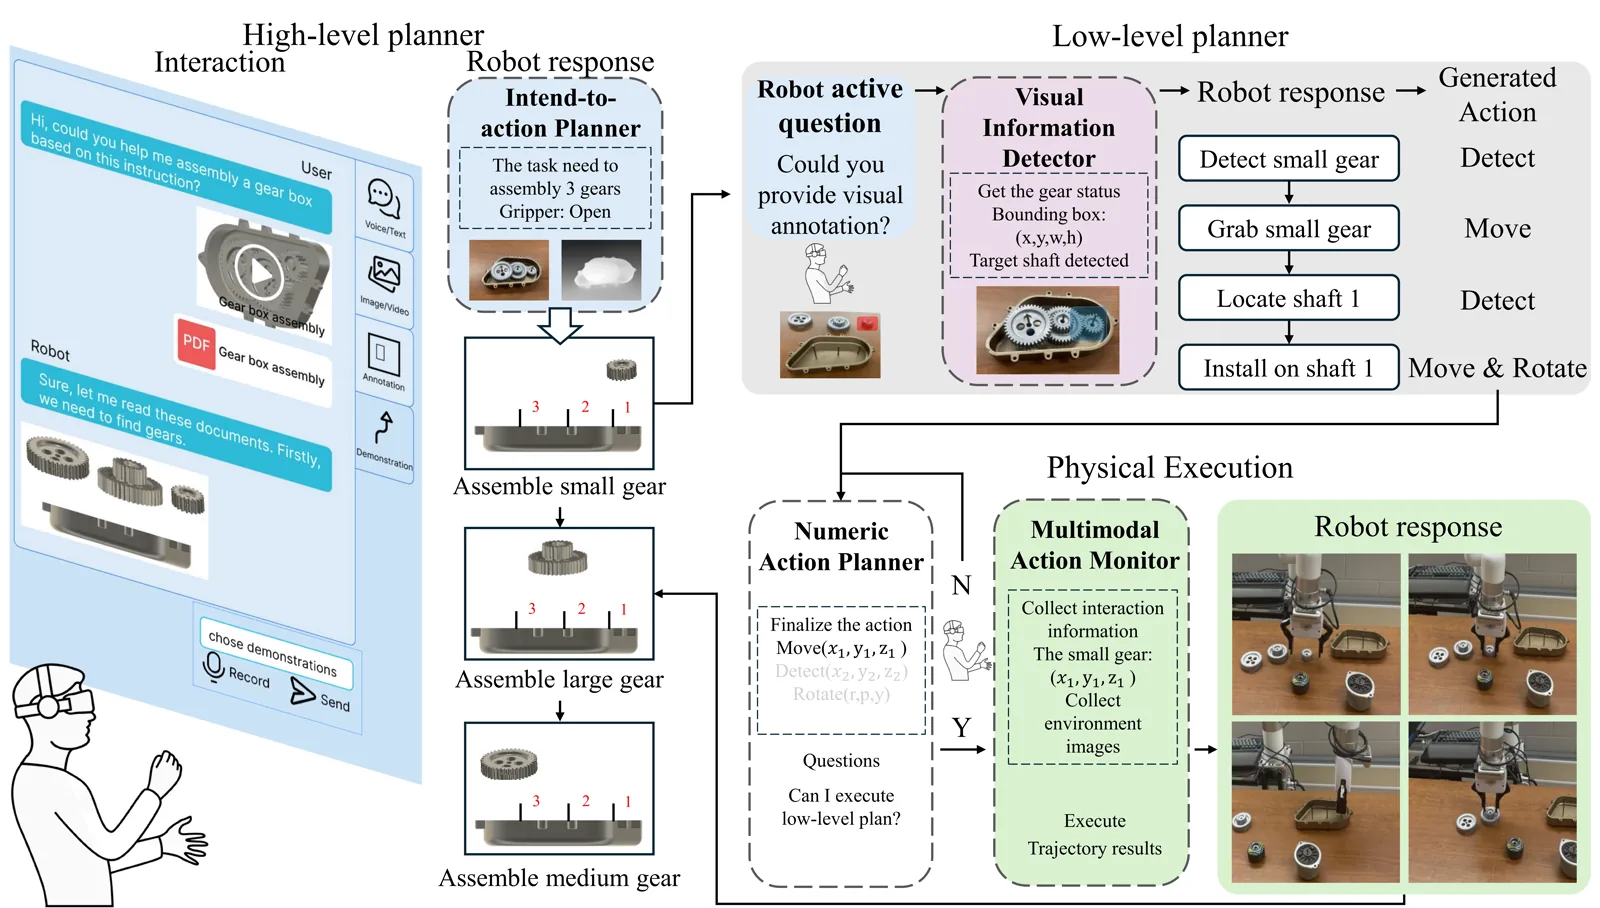
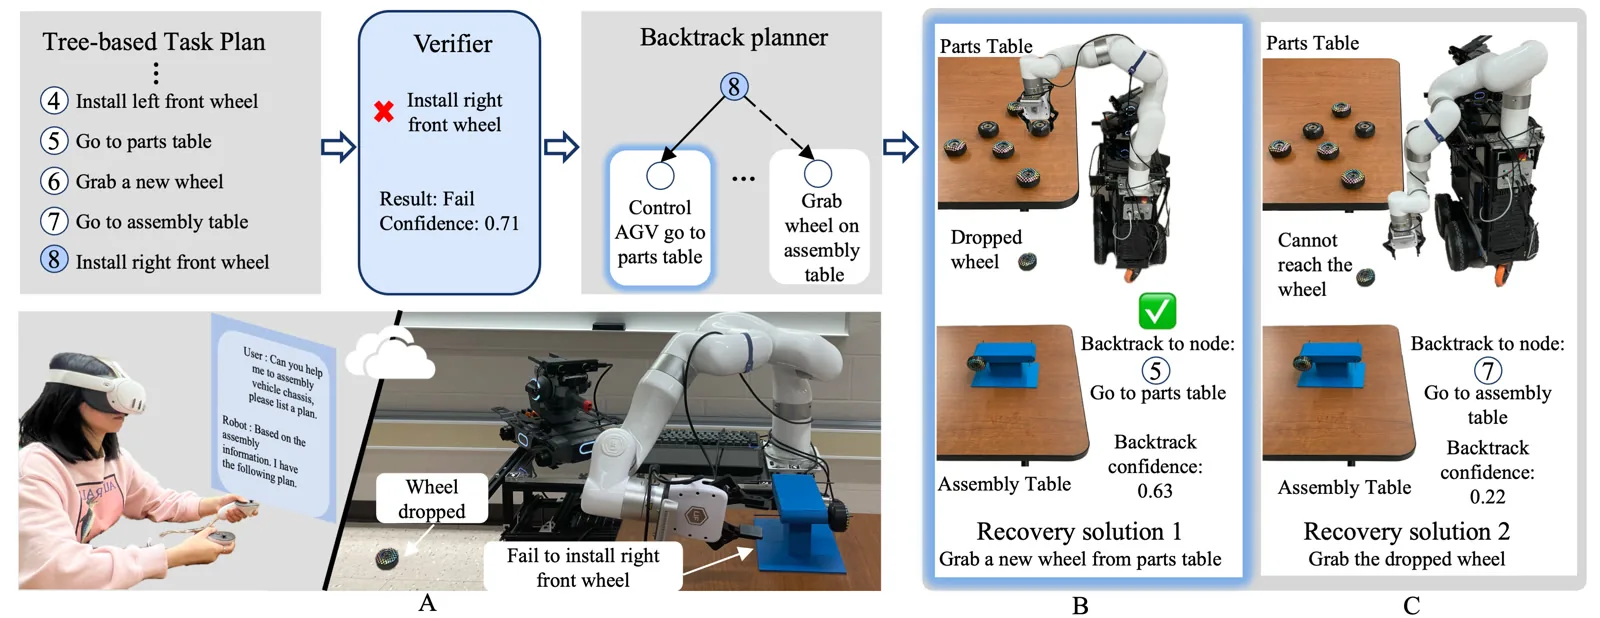
A human-robot collaboration framework that combines multi-expert agents, VLA models, and augmented reality interaction for long-horizon assembly tasks.
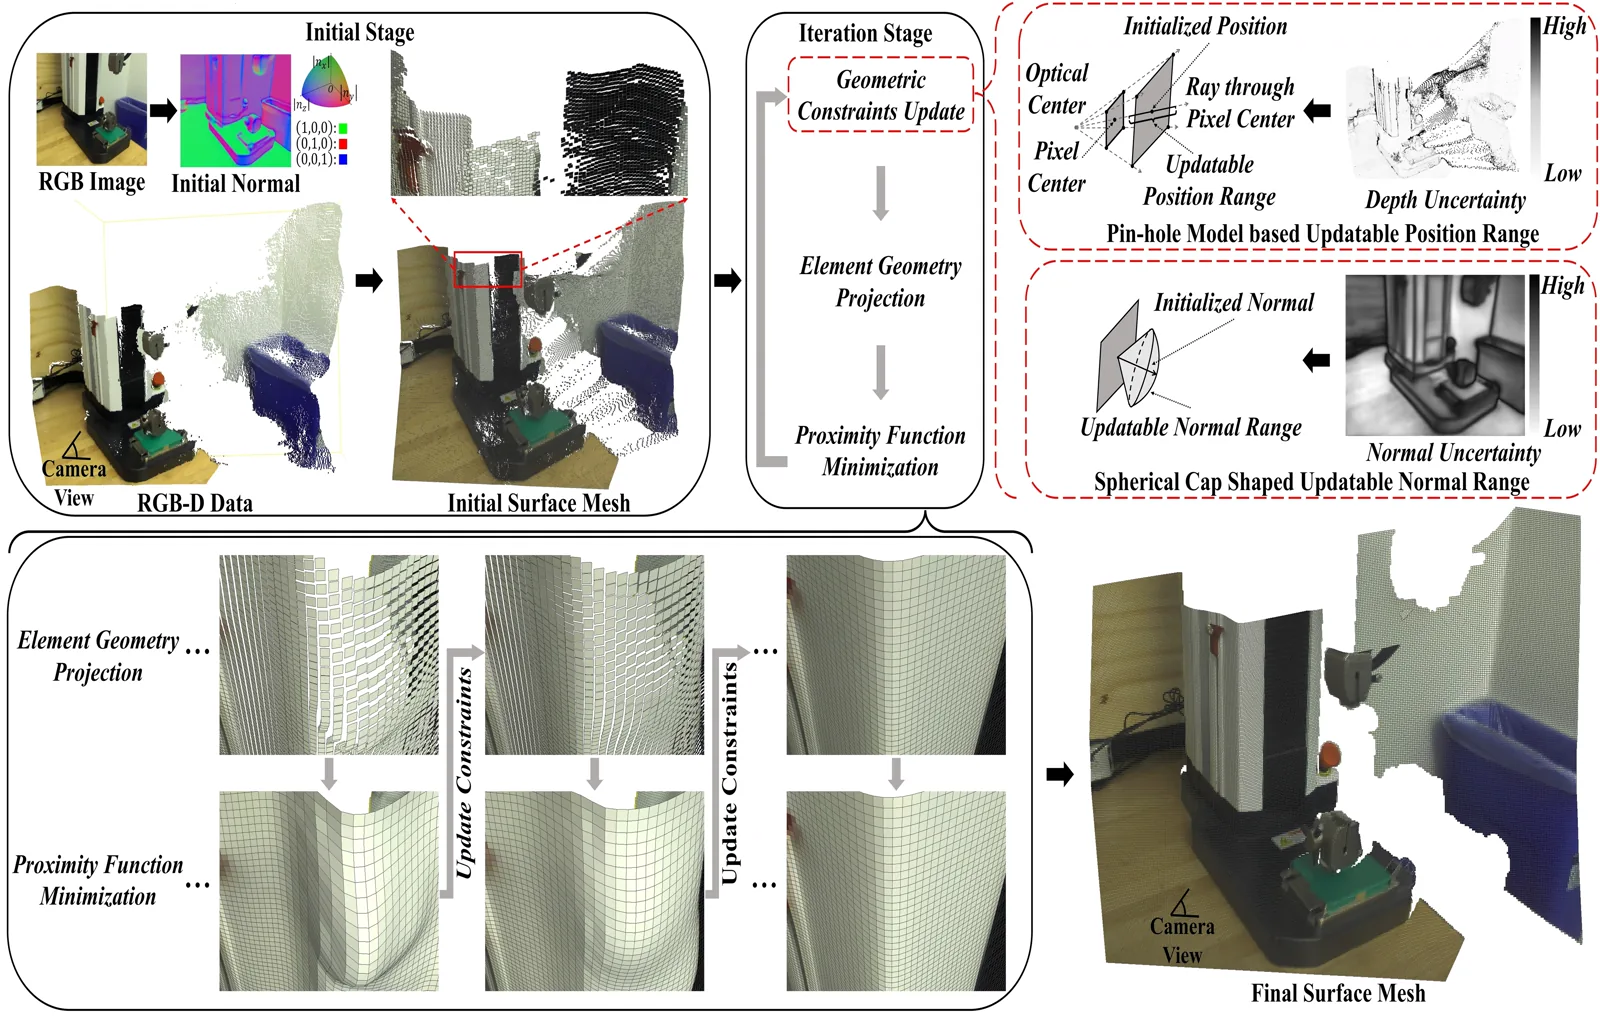
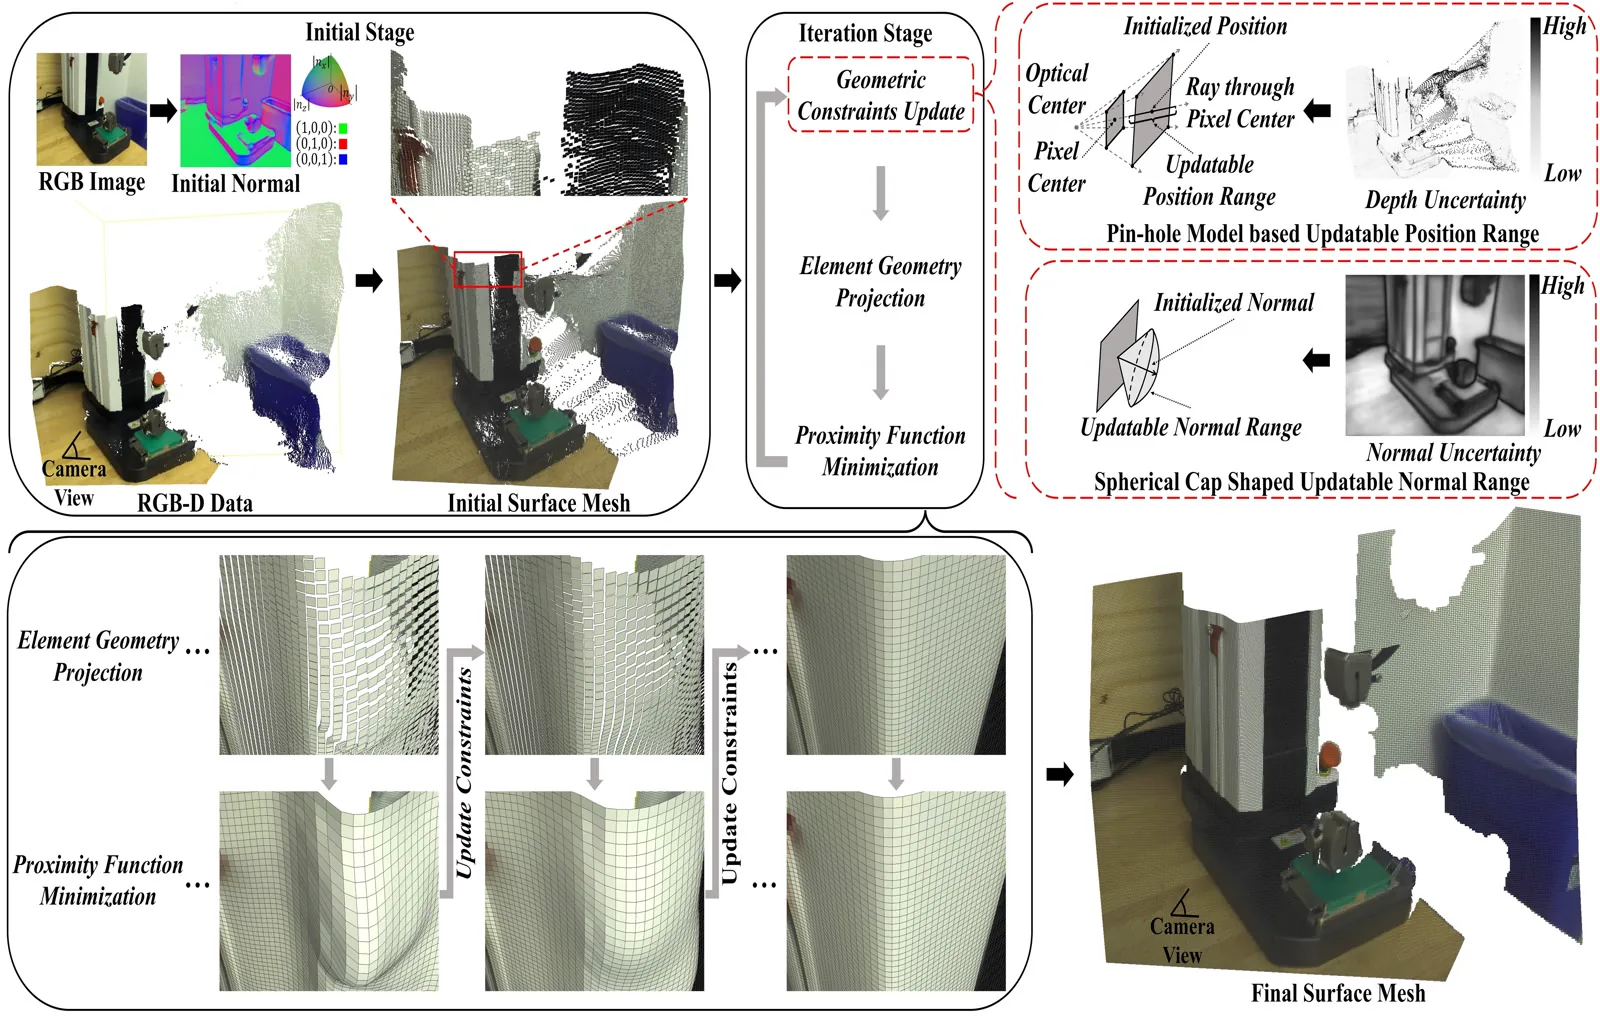
A geometry-processing approach for accurate indoor depth completion, producing sharper object boundaries and reducing distortion in manufacturing environments.
Live demonstrations of embodied AI systems and autonomous robot manipulation.
Weekly group reading sessions and technical discussions on VLA models, foundation policies, and sim-to-real transfer.
Project milestone reviews, team gatherings, and collaborative sessions across robotics and AI disciplines.